By Celia Luterbacher
Imagine a robot designed to install solar panels with much greater speed and precision than a human. The robot is made from expensive materials and powered by a heavy battery that must be recharged every few hours. If the costs of building and operating the robot outweigh the benefits of the clean energy it helps produce, can it really be considered sustainable?
In a 2025 article published in Science, Aude Billard, head of the Learning Algorithms and Systems Lab in EPFL’s School of Engineering and Academic director of the Robotics Center, gives precisely this example to illustrate the tension between robotic performance and sustainability. Roboticists, she argues, can no longer ignore the fact that robots use energy-intensive power systems and electronic components made from finite resources.
At the same time, robots have the potential to contribute to addressing some of society’s most pressing sustainability challenges, for example through environmental and biodiversity monitoring, precision agriculture, and the maintenance of critical infrastructure like bridges, buildings, and power grids.
“Our ambition is not to simply make robots more sustainable; they must actively contribute to solving sustainability challenges.”
– Mirko Kovač, Laboratory of Sustainability Robotics
Beyond sustainable robotics
Current research at the intersection of robotics and sustainability follows two main paths: developing robots that enable a more sustainable use of resources, and developing robots that are themselves more sustainable due to improved energy efficiency, biodegradability, or recyclability.
Mirko Kovač heads the joint Laboratory of Sustainability Robotics at Empa and EPFL’s School of Architecture, Civil and Environmental Engineering. In a cover article recently published in Nature Machine Intelligence, Kovač and his co-authors propose a manifesto that calls on academia, industry, and governments to extend and integrate these approaches within a broader framework that evaluates robots according to their overall contribution to sustainability goals. The manifesto defines a new discipline called Sustainability Robotics (not to be confused with sustainable robotics).
“Our ambition is not to simply make robots more sustainable; they must actively contribute to solving sustainability challenges,” Kovač says.
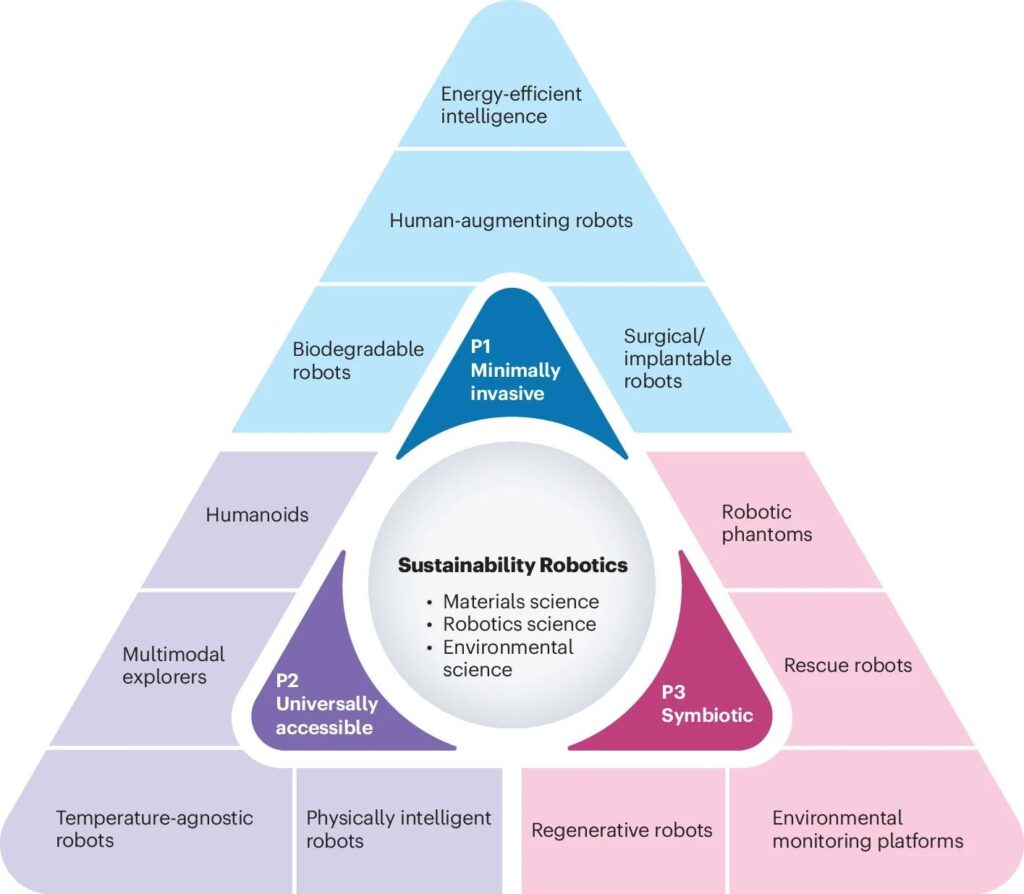 The three core principles of Sustainability Robotics. 2026 LSR/EPFL – CC BY SA 4.0
Minimally invasive, accessible…
In their article, the researchers argue that robots should no longer be evaluated solely based on technical performance. Instead, their environmental, social, and economic impacts should become part of the equation. To guide this transition, they propose three core principles: robotic systems should be minimally invasive, universally accessible, and symbiotic, creating value for people as well as economies and ecosystems.
Rather than viewing sustainability challenges like climate change, biodiversity loss, and resource scarcity as constraints on innovation, the authors argue that they can become opportunities to develop entirely new engineering solutions. Indeed, several EPFL laboratories are already exploring what Sustainability Robotics might look like in practice.
For example, the eel-inspired Envirobot, from Auke Ijspeert’s Biorobotics Lab, supports environmental research by targeting the autonomous monitoring of water quality. The project reflects the lab’s broader efforts to draw inspiration from animals to develop robots capable of operating in complex natural environments while improving our understanding of biological locomotion.
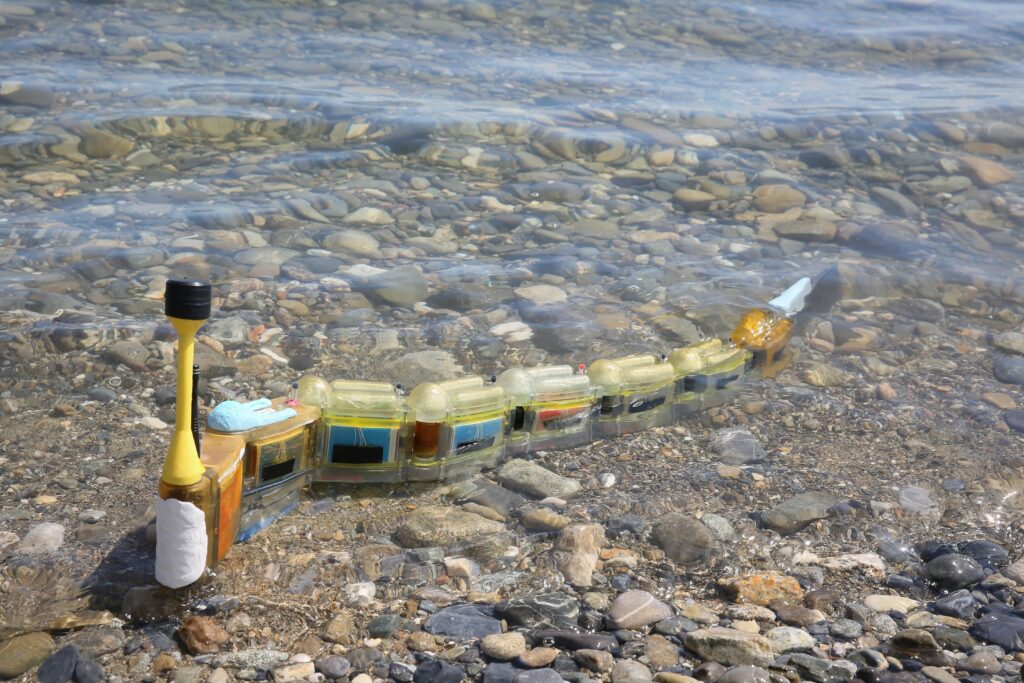 The eel-inspired Envirobot from the Biorobotics Lab supports environmental research by targeting the autonomous monitoring of water quality. 2017 Alain Herzog / EPFL – CC BY SA 4.0.
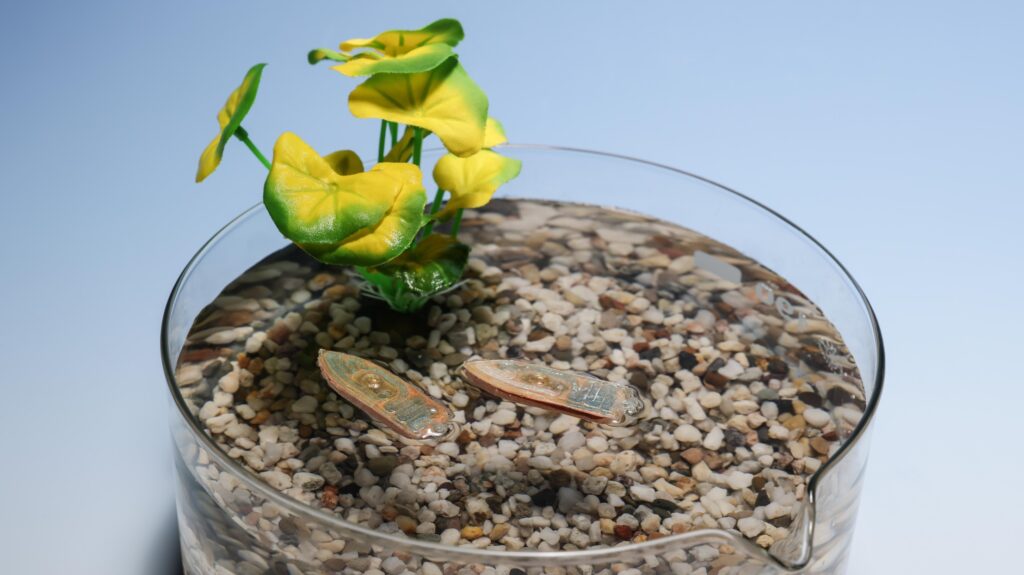
Engineers in the Laboratory of Intelligent Systems, led by Dario Floreano, have developed an aquatic robot made from fish food. Likewise designed for environmental monitoring, the device can be equipped with biodegradable sensors for collecting data like pH, temperature, and the presence of pollutants. At the end of its life, it can also feed aquatic organisms rather than becoming electronic waste.
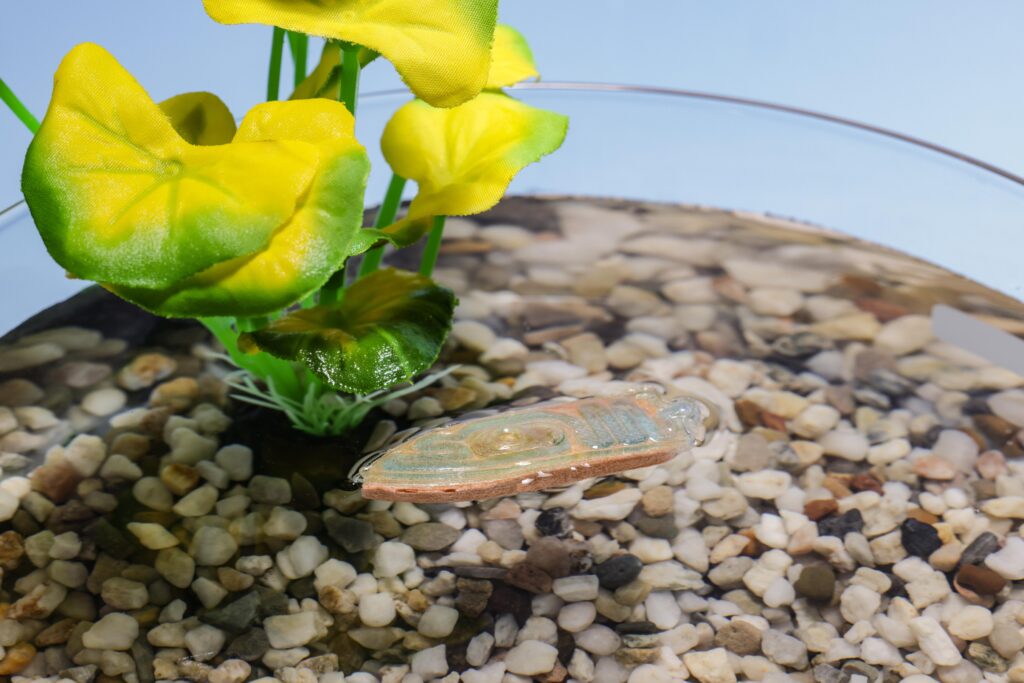 This edible robot from the Laboratory for Intelligent Systems is an alternative to electronic environmental monitoring devices. EPFL – CC-BY-SA 4.0.
…and symbiotic
Sustainability Robotics’ concept of symbiosis also raises questions about how robots can create value across multiple domains. One example is the RoboFood initiative, coordinated by Floreano, which explores edible robots and roboticized food systems. Although food and robots are usually considered to be two separate worlds, Floreano argues that merging them could have advantages for healthcare, food production, and environmental sustainability.
“Edible robots could be used to deliver food to endangered areas, to deliver medicines in innovative ways to people who have difficulty swallowing or to animals, or even to monitor food and its freshness using sensors that can be eaten,” he says. “They could also help limit electronic and food waste.”
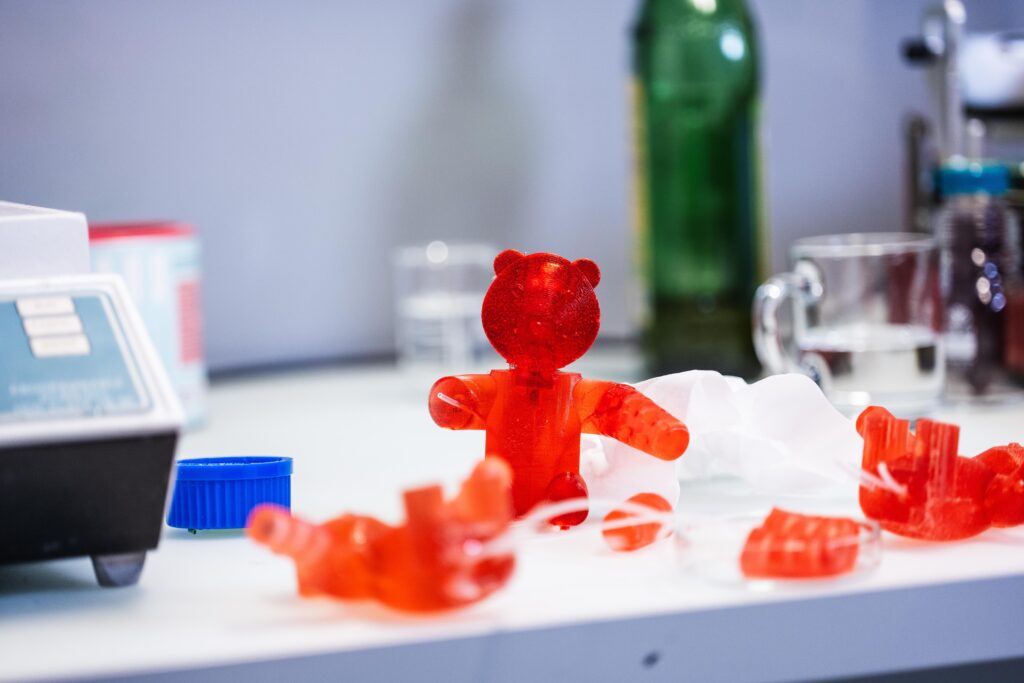 Edible robotic teddy bears, created by the LIS at EPFL – 2025 EPFL/Jamani Caillet – CC-BY-SA 4.0.
Another example comes from the built environment. In the Lab for Creative Computation, Stefana Parascho investigates how robotic workflows, which typically require uniform components and predefined plans, can be adapted to use irregular and reclaimed construction materials. Such approaches could help reduce waste while allowing architects to work with available materials instead of relying exclusively on standardized products. They could also inspire fabrication processes characterized by more adaptive and collaborative human-robot interactions.
In addition to materials and applications, research in the Computational Design and Fabrication (CREATE) Lab, led by Josie Hughes, shows how sustainability can be embedded directly into robot design from the beginning. One way to do this is through simplified, energy-efficient approaches to robotic control, as demonstrated by the quadruped robot PAWS. Once set in motion, the canine-inspired robot can run by itself using compliant materials and synergistic joints, without activating any motors. The project demonstrates how nature can inspire robust locomotion through mechanical design, rather than increasingly complex control systems.
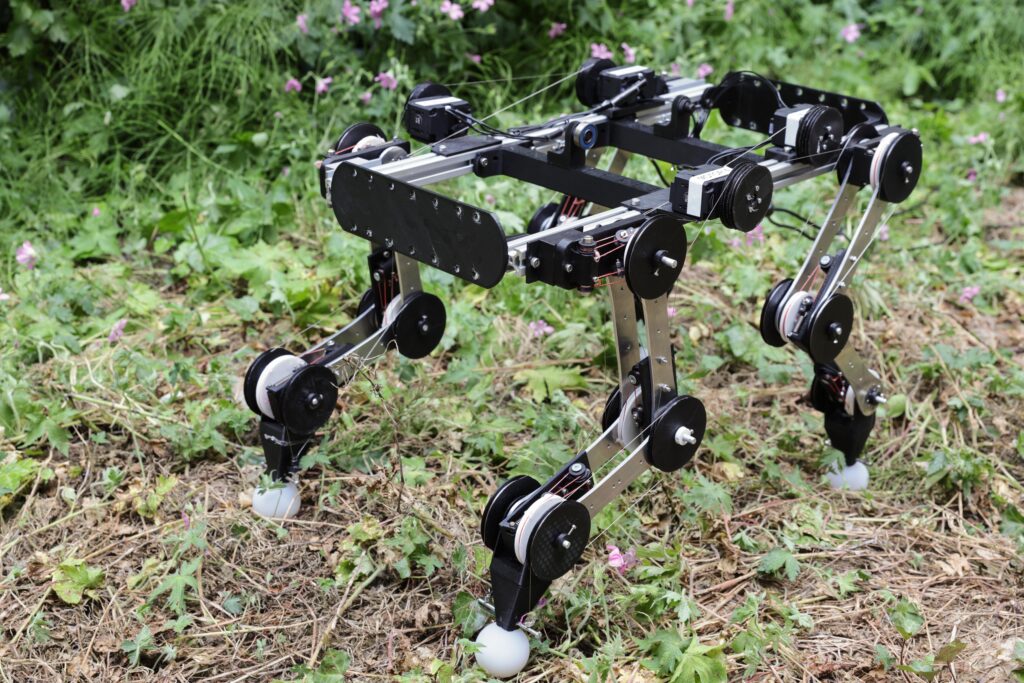 Once set in motion, the CREATE Lab’s canine-inspired PAWS robot can run by itself using compliant materials and synergistic joints, without activating any motors. 2023 Alain Herzog/EPFL CC BY SA -4.0.
A new measure of performance
Ultimately, Billard and Kovač both call for a broader definition of robotic success that accounts for social, economic, and environmental value alongside technical performance. Of course, this won’t be easy; robots designed with sustainability objectives in mind will still require energy and materials to build and operate, and their use will still carry inherent risks. However, as Kovač puts it: “the challenge is not to eliminate these trade-offs, but to make them visible, and account for them when evaluating a robot’s overall impact.”
Many of the projects already emerging from EPFL labs draw inspiration from biological systems that have been refining solutions to the trade-offs between locomotion, dexterity, efficiency, and adaptability for millions of years. In doing so, they suggest a vision of robotics that comes full circle: using lessons learned from nature to better understand and protect it.
In that sense, sustainability may become one of the most important performance metrics for the next generation of robots.
References
- Aude G. Billard. Designing and using robots for environmental sustainability. Science 388, eadx2444 (2025).
- Song, S., Mazzolai, B. & Kovač, M. A manifesto for Sustainability Robotics. Nature Machine Intelligence (2026).
- Empa press release
- Envirobot: A bio-inspired environmental monitoring platform. IEEE/OES Conference on Autonomous Underwater Vehicles (AUV), Tokyo, Japan (2016), pp. 1-6.
- RoboFood
- Skevaki, E., Duong, E., Yang, HB. et al. Crafting structural timber trusses from irregular offcuts via human–robot interaction. Construction Robotics 10, 20 (2026).
- Stefana Parascho. Construction Robotics: From Automation to Collaboration. Annual Review of Control, Robotics, and Autonomous Systems 6:183-204. 2023.
- Stella, F., Achkar, M.M., Della Santina, C. et al. Synergy-based robotic quadruped leveraging passivity for natural intelligence and behavioural diversity. Nature Machine Intelligence 7, 386–399 (2025).
- Zhang, S., Kwak, B., Zhu, R. et al. Edible aquatic robots with Marangoni propulsion. Nature Communications 16, 4238 (2025).