Six-legged robot learns to walk from a stick insect
Do you ever see an ant skittering across your kitchen counter and wonder how this little bug overcame all the obstacles in your home just to get there? Insects use their tiny nervous systems to walk with surprising dexterity—a skill that could be transferred to robots looking to do more productive things than just find breadcrumbs in your kitchen.
AI searched 100 million possibilities and found a cheaper way to 3D-print a NASA rocket alloy
Researchers used AI to search through more than 100 million possible settings for 3D-printing a high-performance NASA alloy. After only 40 experiments, the system identified six successful configurations, including one that worked at a record-low 500 watts. That could allow GRCop-42, currently difficult and expensive to print, to be made with much more widely available equipment.
From cartwheels to backflips, motion-imitation framework teaches three robots dynamic movements
Legged robots, robotic systems with legs that typically resemble those of animals or humans, could be advantageous for completing tasks in home environments or populated, dynamic spaces. These robots may look like humans or animals, yet they often cannot reliably replicate complex whole-body movements in a short time.
Piloting the world’s first double-blind AI evaluations
Piloting the world's first double-blind AI evaluations
Sunrise Robotics Accelerates Automation with AI-powered GoFa™ cobot cells
Sunrise Robotics needs its autonomous cells to perform precise manipulation for high-mix manufacturing, including pick & place, positioning, and machine-tending operations in human-centric environments.
NASA just used satellites and debris to navigate without GPS
NASA has successfully tested a system that allows satellites to navigate without GPS by using other spacecraft and debris as landmarks in orbit. In just three days, FALCON also improved the known orbits of more than 200 space objects completely autonomously.
Intelligent transcription with Gemini 3.5 Transcribe
Now you can get more intelligent speech-to-text transcription with Gemini 3.5 Transcribe.
Giant cyborg cockroaches could bring supervised care to people trapped beyond rescuers’ reach
"Swarms" of cyborg cockroaches with cameras and miniature medical injectors could deliver supervised emergency care to people trapped in collapsed buildings, caves or other places too dangerous for rescuers to reach. The "Paraborgs" developed by University of Queensland biorobotics researchers, working with biomedical engineers at the University of New South Wales (UNSW), move cyborg insects of the future beyond searching for survivors to actively assisting them. The research is published in the journal Advanced Science.
New underwater robot could make ocean missions more reliable
A new, patent-pending underwater robot developed at Purdue University's College of Engineering could improve ocean research, underwater infrastructure inspection and search-and-rescue efforts by adapting to mission needs in real time, acting as a drifter, a glider or a thruster-driven vehicle when necessary.
ScaFi: A robot that grows like a fish, not a machine—from 2 feet to nearly 10
Propeller-powered underwater vehicles have long helped scientists explore and monitor aquatic environments. But they're limited by their own mechanics: Spinning blades can snag on vegetation, stir up sediment and startle the wildlife they're often sent to study, making them poorly suited to shallow creeks, dense weeds or close encounters with fish.
Hand in hand
The integrated machine vision software MVTec MERLIC significantly enhances quality assurance in the assembly process by displaying all relevant information for assembling the component to the production worker, then verifying the process and documenting quality.
How green is your robot? And other awkward questions
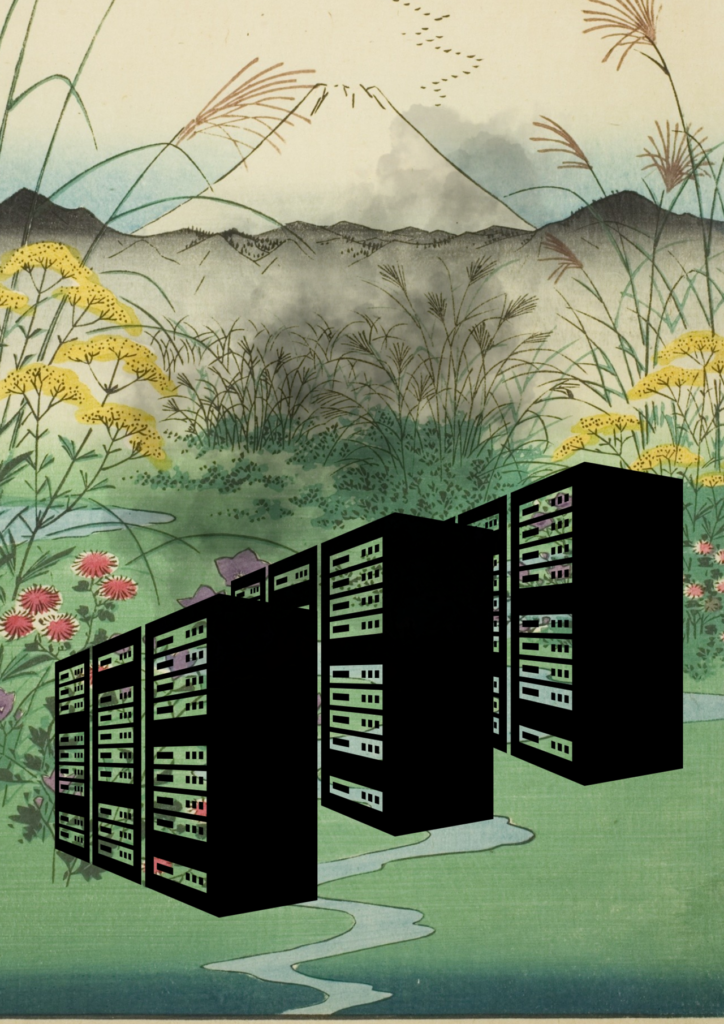 Deborah Lupton / Servers in a Landscape / Licenced by CC-BY 4.0
By Emmet Cole
Robots clean rivers and sort waste, monitor ecosystems, and inspect renewable-energy infrastructure. But even the greenest robot has an environmental footprint.
If robotics is going to help build a more sustainable world, the robotics community has to answer some potentially awkward questions, starting with this one: How sustainable are robots themselves?
Across a full lifecycle, from rare earth mineral extraction and manufacturing to operation and end-of-life, robots have an environmental impact. But the robotics community has, until now, lacked dedicated tools for calculating it.
The Robotics Eco-Label project, led by Bram Vanderborght at Belgium’s Vrije Universiteit Brussel, is an attempt to address that gap with a lightweight, web-based Toolkit that provides roboticists with a way to quantify robot sustainability.
Separating a robot’s core technologies into materials, energy sources, sensors, processors, actuators, design, and recyclability, the Robotics Eco-Label Toolkit then evaluates each based on five metrics: resource conservation, lifecycle extension, carbon footprint, energy efficiency, and circularity. The numbers are combined in a weighted matrix to yield a 0–100 Eco-Score for Robots. The weights used are not currently fixed; that will be one of the targets of further research and collaboration. (For an indicative score on your robot, try the project’s interactive self-assessment tool here.)
A low score in one area might point to energy-hungry actuators, limited repairability, hard-to-recycle materials, or a lack of end-of-life planning. A higher score, by contrast, suggests that sustainability has been considered across the system. One of the project’s stated goals is to make environmental trade-offs visible early enough in the development process to shape sustainable robot design choices.
The project also includes educational content and community features so researchers and developers can compare approaches, share case studies, and turn broad sustainability goals into improved design decisions. For companies, Eco-Label could well turn out to be a way to achieve competitive advantage, while it could also help buyers make more informed decisions.
Robotics Eco-Label is just one of the IEEE RAS Sustainability Grant-funded projects showcased at ICRA in June. The grants are a key component of IEEE RAS’ broader effort to make sustainability a more visible part of robotics research, education, design, and deployment.
Are you buying more robot than you need?
Sometimes, sustainable robotics starts with better purchasing decisions. This includes avoiding overspecification; that is, buying robots that are larger or more capable than necessary.
Matching robots to their intended workload can reduce unused capacity, avoid unnecessary material use, and cut wasted energy over a robot’s life cycle.
That principle underpins the work of an IEEE RAS-funded team, led by Antun Skuric, that has developed an open-source platform for assessing the sustainability of collaborative robots.
To use it, you define a required workspace, payload, and trajectory, and the platform identifies the minimum-mass robot that satisfies your application requirements.
The application features interactive tools that enable users to visualize and jog the robot, inspect task-related variables and requirements, view the reachable space, and observe important robot configurations. This enables robot performance to be calculated based on specific task conditions and requirements.
Can robots really help communities overcome energy poverty?
Energy poverty and inefficient solar energy utilization are major challenges in Nigeria, where more than 90 million people lack reliable electricity access.
The SolarPeer 360 project, led by Umar Adetola Abdulganiyy, a student at the Federal University of Technology, Minna, Nigeria, takes on this challenge through a combination of robotic solar tracking, AI-assisted optimization, and peer-to-peer energy distribution.
A timely reminder that robots can help support sustainability goals directly, SolarPeer addresses two connected problems, inefficient small solar installations and the lack of transparent, affordable mechanisms for sharing surplus renewable energy among households and small businesses.
According to the team, SolarPeer 360 is built on a sustainability logic in which “energy captured more efficiently can be shared more fairly, and energy shared more transparently can create local economic value while reducing waste and fossil-fuel dependence.”
SolarPeer links smart solar capture through tracking, controlled and metered distribution through embedded electronics, and behavior optimization through data, interfaces, and AI guidance.
Early results indicate meaningful gains: The team reported a 60.3 percent gain in average power in one tracked-versus-fixed solar comparison, with measured average power rising from 3.83 W to 6.14 W. Meanwhile, AI-guided energy advisory and optimization contributed to a ~25 percent reduction in energy wastage in the testing environment.
Beyond the lab, the team deployed five community mini-systems and ran a solar training and empowerment workshop that reached more than 500 students.
Can Caretta work faster?
Sustainability in robotics is not just a technical challenge. It’s also a cultural and educational challenge for the next generation of engineers, researchers, teachers, and users.
That’s part of the reasoning behind the ‘Caretta’ project, led by Mustafa Kemal Ambar, which brought robotics and sustainability education to students aged 8 to 16 on the island of Cyprus.
Inspired by the Caretta sea turtle, the project produced a functional robot prototype designed to reduce coastal pollution. Two successful coastal clean-up events were held and more than 30 students were engaged in the project through seminars and hands-on learning.
Treating the beach as both a test site and a classroom, students saw how engineering connects to local environmental problems and community needs.
During a field exercise, one student pointed to plastic debris near the water and observed: “Maybe turtles won’t eat this anymore if Caretta works faster.”
Can the robotics community work faster to build sustainability into its foundations and practices? Early results from IEEE RAS Sustainability Grant projects suggest that work is already underway.
Want to learn more?
RAS University now has a free new class on Sustainable Robotics, you can learn more here.
You can also follow activities from the Sustainability and Climate Change Committee, including upcoming grant calls here.
This article originally appeared on IEEE RAS.
Humanoid robot breaks 100-meter mark with 8.86-second sprint in Beijing
A Chinese humanoid robot set a new 100-meter sprint record of 8.86 seconds in Beijing on Tuesday, beating its robot competitors — and the fastest recorded human time.
How to Select the Best Motor for Mobile Robots and Automation
A mobile robot is a chain of compromises where the motor, gearbox, controller, battery, wheels, and mechanical layout constantly influence one another. Looking at any of them in isolation almost always leads to a second design iteration.